Black Box ControllerSystem identification and PID design
Identified an unknown plant from sampled outputs alone, then designed a feed-forward and PID controller that exceeded every target spec. Top of the class.
- Year
- 2023
- Category
- Research
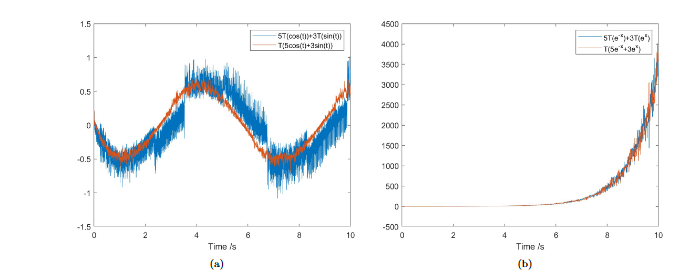
We were handed a black box with an unknown transfer function and could only observe samples of its output at regular intervals. The task was to characterise it well enough to design a controller that makes the output track the input exactly.
That meant proving the system was time invariant, estimating the noise and justifying a low-pass filter with Fourier analysis, building a Bode plot with an efficient frequency sweep, fitting a transfer function and adding feed-forward compensation to make the system minimum phase, and finally designing and tuning a PID controller. The controller exceeded every target specification and was ranked top of the class.